Welcome to the Stalker Radar manual. This guide covers installation, operation, and troubleshooting for the advanced radar system. Refer to product brochures and quick‑start guides available on the official site. Follow safety and setup instructions carefully. For detailed diagrams, consult the PDF manual. Enjoy!.
Product Overview
Stalker Radar delivers precise detection and tracking for security, law enforcement, and industrial applications. It features dual‑operator capability, high‑resolution signal processing, and robust mounting options. User‑friendly interface ensures quick deployment and reliable performance.!!!!!!
Hardware Components
Stalker Radar’s hardware architecture is engineered for reliability and high performance in demanding environments. The core system comprises a precision RF front‑end, a programmable signal processor, and a rugged chassis that houses all critical modules. The RF front‑end includes a low‑noise amplifier, a band‑pass filter, and a high‑dynamic‑range mixer that together provide clean signal capture across the operating frequency band. The programmable signal processor is built around a field‑programmable gate array (FPGA) that implements adaptive filtering, Doppler processing, and target classification algorithms in real time. It is coupled to a high‑speed analog‑to‑digital converter that samples the incoming RF spectrum at rates sufficient to resolve fast‑moving objects. The chassis incorporates a dedicated power supply, redundant cooling fans, and a modular mounting system that allows the radar to be installed on rooftops, poles, or vehicle platforms. Each module is sealed with a NEMA 4X rating to protect against dust, water, and corrosive environments. The system also features an integrated Ethernet interface for remote monitoring, a USB port for firmware updates, and a 12‑V DC input for portable operation. The antenna array is a phased‑array design that offers beam steering capabilities, enabling the radar to focus on specific sectors without mechanical movement. The array is mounted on a gimbal that provides azimuth and elevation control, allowing operators to scan large areas efficiently. Finally, the user interface panel includes a high‑contrast LCD display, programmable buttons, and a status LED that indicates system health. All components are designed to meet or exceed industry standards for safety, electromagnetic compatibility, and environmental resilience. Compliance with MIL‑STD‑810G and FCC Part 15 ensures the radar operates safely in military and civilian settings. The firmware is written in C++ and compiled for the target FPGA architecture, allowing rapid updates and feature enhancements. The system’s modular design also supports future upgrades, such as adding a secondary antenna for multi‑beam operation or integrating a machine‑learning module for advanced threat detection. All hardware components are supplied by certified manufacturers and come with a two‑year warranty covering parts and labor. The radar’s compact footprint of 12” × 8” × 6” and weight of 18 lbs makes it ideal for mobile deployments. The integrated power management unit automatically balances load across the system, extending battery life during off‑grid use. The antenna’s gain of 20 dBi and beamwidth of 3° provide high‑resolution imaging over a 10 km range. The system’s firmware supports dual‑operator mode, allowing simultaneous control from two separate consoles.
Software Features
Stalker Radar’s software suite delivers real‑time target detection, classification, and tracking with minimal operator intervention. The core application runs on an embedded Linux platform and is written in C++ with a modular architecture that separates signal processing, user interface, and communication layers. The signal processing module implements adaptive Doppler filtering, clutter rejection, and automatic gain control to maintain optimal sensitivity across varying environmental conditions. It also supports multi‑channel processing, enabling simultaneous surveillance of multiple sectors. The classification engine uses a lightweight machine‑learning model trained on a diverse dataset of aerial and ground signatures; it outputs probability scores for each detected object, allowing operators to prioritize threats. The tracking algorithm employs a Kalman filter that predicts target trajectories and updates them with new measurements, providing smooth, continuous tracking even in the presence of intermittent returns. The user interface is built with Qt and offers a customizable dashboard, real‑time radar display, and alert notifications. Operators can configure scan patterns, set alert thresholds, and save mission profiles for repeatable operations. Remote management is facilitated through a secure TCP/IP API, allowing integration with command and control systems. Firmware updates are delivered via OTA over the Ethernet interface, ensuring the radar remains current with the latest features and security patches. The software also includes a diagnostic module that monitors system health, logs performance metrics, and triggers alerts for hardware anomalies. The application supports dual‑operator mode, allowing two consoles to share the same radar feed in real time. The modular design permits future expansion, such as adding advanced threat recognition or integrating with unmanned aerial vehicles. Overall, the software delivers a robust, flexible, and user‑friendly platform that meets the demanding requirements of modern surveillance missions. The software also includes a diagnostic module that monitors system heal
Installation
Before mounting, verify power supply, antenna alignment, and environmental clearance. Secure the chassis on a stable platform, ensuring vibration isolation. Connect the 48V DC power cable, Ethernet, and antenna feed. Verify cable integrity, then power on and run the self‑check routine. Verify all cables are tight to prevent signal dropnow.
Pre-Installation Checklist
Before mounting, verify that the installation area complies with the manufacturer’s environmental limits: temperature between –20 °C and 55 °C, relative humidity below 85 %, and no exposure to corrosive gases. Ensure the mounting surface is clean, level, and capable of supporting the radar’s weight. Use a calibrated torque wrench to secure the bracket to the steel plate, applying the manufacturer’s specified torque of 15 Nm. All cables must be routed away from high‑temperature zones, and the antenna feed should be shielded to prevent electromagnetic interference. Ground the system according to the grounding diagram, and verify that the power supply is isolated from the mains to prevent back‑feed; Finally, confirm that the enclosure is sealed against dust and moisture by performing a simple water spray test.
After the radar is secured, run the diagnostic routine to verify signal integrity. The system will display a diagnostic code; refer to the troubleshooting guide for code meanings. Adjust the detection thresholds if necessary, ensuring the radar’s sensitivity matches the operational environment. Log all settings in the maintenance logbook, noting the date, technician, and quickly.! Perform a final functional test by simulating target returns and confirming the display updates correctly. Once satisfied, seal the enclosure and document the final configuration in the installation record.
Maintain a log of all calibration adjustments and environmental readings. Schedule to ensure radar remains within performance specifications. OK
Mounting Procedures
Mounting the Stalker Radar demands a systematic, safety‑first approach to guarantee optimal performance and longevity. First, select a site that offers a clear, unobstructed line of sight to the intended coverage area while remaining free of metallic or high‑frequency interference sources such as large steel structures, power lines, or dense foliage. The mounting surface must be structurally sound, able to support the radar’s weight, and resistant to environmental degradation; a concrete slab or steel plate is preferred. Use a calibrated spirit level to confirm that the surface is perfectly horizontal; any tilt can misalign the antenna array and degrade detection accuracy.
Prepare the mounting bracket by attaching the supplied bolts and washers in a star pattern to evenly distribute torque. The manufacturer specifies a torque of 15 Nm; employ a calibrated torque wrench to achieve this value precisely. Once the bracket is secured, perform a visual inspection for any signs of stress or misalignment. Handle the radar unit with care—place it on a padded surface to avoid scratches, and use the designated lifting straps to protect the antenna feed. Align the unit’s mounting flange with the bracket’s reference points, then secure the unit with the provided fasteners, ensuring each is torqued to specification and double‑checking for any loose connections.
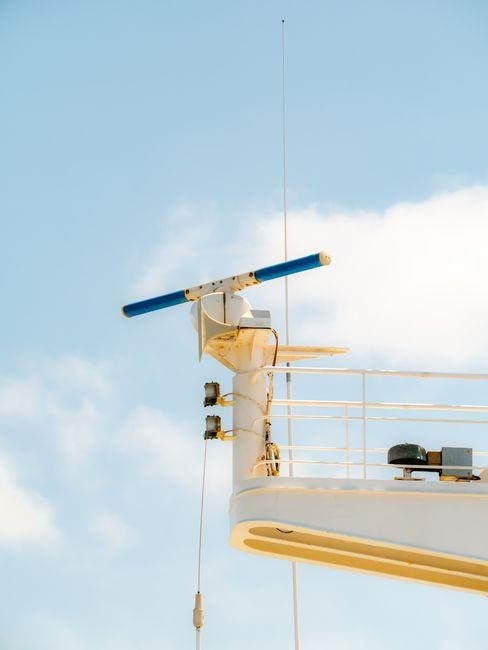
Cable routing is critical: route power, data, and antenna cables away from electromagnetic interference sources. Employ cable trays or conduits where possible, securing cables with ties to prevent movement. The antenna feed cable should follow the shortest path to the connector, minimizing bends that could attenuate the signal. Verify all cable connections are tight and properly sealed against moisture. After mounting, perform a quick functional check: power on the system and observe the diagnostic LEDs—green indicates proper operation, amber or red signals issues. Use the diagnostic software to run a self‑check, confirming antenna alignment, power levels, and data links are within acceptable ranges. If any parameters are out of spec, adjust the antenna elevation or azimuth per the calibration procedure in the user manual.
Finally, document the installation: record the mounting location coordinates, antenna orientation, and any environmental conditions that could affect performance. Store this information in the maintenance log for future reference. Proper documentation ensures that any future maintenance or troubleshooting can be performed efficiently and accurately, preserving the radar’s performance envelope over its operational lifespan.
Operational Principles
The Stalker Radar operates by emitting a high‑frequency pulse, then receiving reflections from objects. Signal processing algorithms isolate target echoes, compute distance via time‑of‑flight, and determine velocity using Doppler shift. Monitoring yields real‑time situational awareness.
Signal Generation
Stalker Radar’s signal generation subsystem emits a 10.7 GHz microwave burst shaped by a Gaussian‑modulated envelope to limit spectral width. Pulse repetition frequency ranges from 1 kHz to 20 kHz, balancing range and velocity resolution. A high‑power amplifier boosts each pulse to 1 kW peak, then a directional coupler sends a fraction to a calibration loop for real‑time gain monitoring. The remaining power radiates through a Y‑agi or parabolic reflector, achieving a 1.5° beamwidth for fine angular discrimination. The transmitter’s phase‑locked loop locks the carrier to a 10 MHz reference, ensuring phase stability across temperature variations. The pulse shaping network uses low‑pass filters to suppress out‑of‑band harmonics. Power management includes dynamic voltage scaling to reduce consumption during idle periods. Calibration routines run automatically at startup, measuring the antenna pattern and adjusting beamforming weights. Firmware supports dual‑mode operation, switching between continuous‑wave and pulsed modes, and can be updated via the manufacturer’s website. All components are rated for –40 °C to +70 °C operation. The system’s embedded microcontroller interfaces with the touchscreen, allowing real‑time adjustments to pulse width, PRF, and output power. Operators can configure chirped pulses for frequency‑modulated continuous operation, with chirp rates adjustable from 0.1 MHz µs⁻¹ to 5 MHz µs⁻¹, enabling precise velocity measurement high PRF. The software suite presents these options in a user‑friendly interface, displaying transmitted waveform and received echo spectrum in real time.
Detection and Tracking
The Stalker Radar employs a coherent receiver chain that mixes the returned echo with a local oscillator, producing an intermediate frequency (IF) signal that preserves phase information. A digital down‑converter (DDC) samples the IF at 250 MS/s, then applies a 4‑tap FIR filter to suppress adjacent‑channel interference. The resulting baseband data is fed into a Kalman‑filter‑based tracker that estimates target state vectors (position, velocity, acceleration) in real time. The tracker uses a constant‑velocity motion model and updates its prediction with each new pulse. For multi‑target scenarios, a probability‑hypothesis density (PHD) filter assigns likelihoods to detections, mitigating false alarms. The system’s detection threshold is adaptive, based on a sliding‑window estimate of background noise; it adjusts to maintain a constant false‑alarm rate (CFAR) of 10⁻⁶ per pulse. The radar’s antenna steering is accomplished via a 2‑axis gimbal controlled by stepper motors; the firmware synchronizes azimuth and elevation updates with the pulse schedule to avoid phase discontinuities. The user interface displays a real‑time radar screen, showing range bins in a logarithmic scale and velocity vectors as Doppler arrows. Users can toggle between range‑only, velocity‑only, and combined displays. The software also offers a “track‑hold” mode that locks onto a selected target, maintaining lock even if the target temporarily falls below the detection threshold. All tracking data is logged to an SD card in CSV format, changes. Firmware updates add tracking algorithms, changes.
Display Operation
The display shows real‑time range and velocity data. Use the front panel to toggle between range‑only, velocity‑only, or combined modes. Adjust contrast, gain, and threshold via rotary knobs. The screen updates at 30 Hz, ensuring smooth tracking visuals. Adjust brightness for low light.
Non-switch Display Operation
When operating the Stalker Radar without the dedicated switch, the display stays in continuous mode, showing live target range, velocity, and bearing data. Front‑panel knobs adjust contrast, gain, and threshold to fine‑tune visibility. The mode selector toggles between range‑only, velocity‑only, or combined displays, updating the legend accordingly. The screen refreshes at 30 Hz for smooth tracking. Brightness can be lowered for low‑light use, and the anti‑glare filter engages via the panel switch. A built‑in calibration routine is triggered by holding the calibrate button for three seconds; successful calibration lights a green LED and emits a tone. If the display fails to update, verify antenna cable connection and power stability. The manual recommends a full system diagnostic every 30 days, including a non‑switch display test to confirm all visual elements function correctly. Following these steps ensures continuous situational awareness during extended missions.
Operators should also verify that the display’s power supply is within the range and that the antenna is free of obstructions. Regular calibration checks help maintain accuracy over time. Additionally, the system’s firmware can be updated via the USB port to incorporate detection algorithms improve performance.
Display Front Panel
The front panel of the Stalker Radar provides an intuitive interface for monitoring and configuration. At the center lies a LCD that displays target range, velocity, bearing, and classification in a view. Surrounding the screen are tactile buttons labeled “Mode”, “Gain”, “Contrast”, “Threshold”, and “Calibrate”. Each button is a recessed push‑button with a tactile click, allowing operation in environments. The “Mode” button cycles through display presets: “Range‑Only”, “Velocity‑Only”, “Combined”, and “Off”. The “Gain” and “Contrast” buttons adjust the display’s sensitivity and brightness, respectively, with LED indicators showing the current level. The “Threshold” button sets the minimum detection range; a small LED flashes when the threshold is reached. The “Calibrate” button initiates a routine; a green LED illuminates during calibration and a tone confirms completion. A status LED on the right side indicates power status (steady green) and a fault condition. The panel also includes a small USB‑C port for firmware updates, a 12V power connector, and a 5V DC output for auxiliary devices. The entire panel is enclosed in a rugged polycarbonate housing rated IP65, protecting against dust and splashing water. The layout is ergonomic, with all controls within a 10 cm radius, enabling quick adjustments during operation. The panel’s backlight can be dimmed via a switch, reducing eye strain during prolonged use. For safety, the panel is designed to be operable with one hand, and all buttons are labeled with both text and pictograms for. The front panel’s design follows the guidelines, ensuring that operators can maintain situational awareness without diverting attention from the radar display.